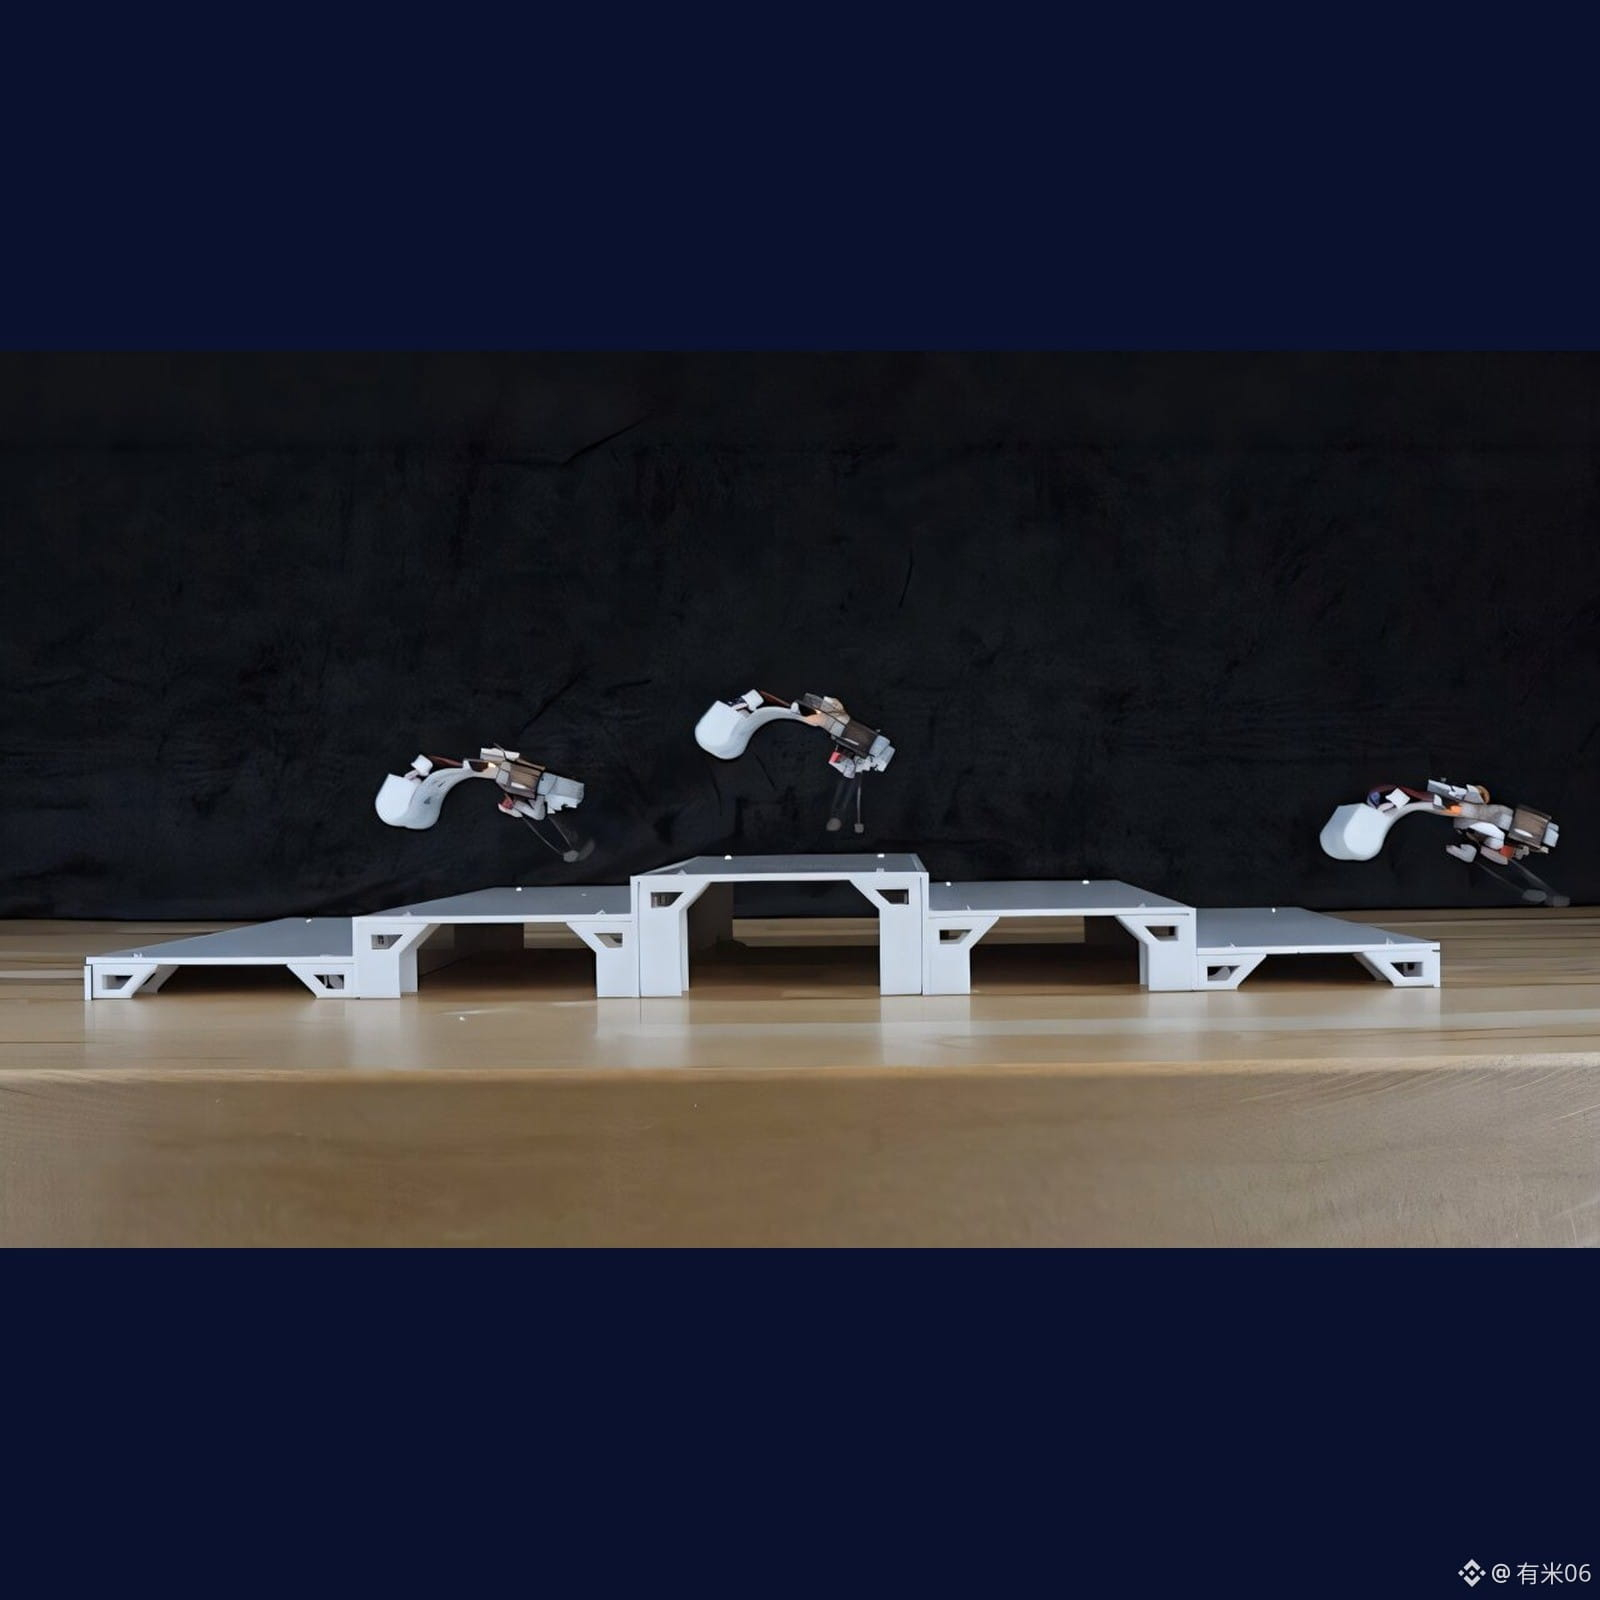
This little robot hops by “twisting a spring.”
UCLA and Michigan twist elastic rods into a spiral; when they reach a critical point, it snaps open with a pop—like a frog kicking its legs, releasing the stored energy all at once. The prototype is only 11 centimeters and 98.2 grams. It can run on six kinds of ground—wood, cloth, acrylic, leather, grass, and sand—and can also go up stairs and even do backflips. With thin fins installed, it can swim backward at about half a body length per second.
In Science Advances, the comparison is striking: the spring-loaded legs reach the fastest on wood at 3.21 body lengths per second, with an average of 2.46 across the six surfaces. For rigid legs with the same setup, it’s only about 0.79. The authors also note that the key is the shape of the rod, which determines when it makes a strong springing move—not fitting in a bigger motor.
#机器人 #仿生