


Zhizhi.com
Author | ZeR0
Editor | Mo Yin
Zhizhi.com reported on August 24. On August 21, at the Arm physical AI robotics technology research global head Federico Pecora’s keynote speech at the World Robot Conference WRC 2026 developer day, Federico Pecora shared industry thoughts on how physical AI is moving from “capability stacking” to “system-level adaptation.”
Arm physical AI robotics technology research global head Federico Pecora delivered a keynote speech
In the past few years, robots have made significant progress in fields such as perception, cognition, and motion control, and application boundaries have continued to expand. However, when robots move beyond pre-defined rule environments and enter real-world settings with crowded people and many random variables, breakthroughs in single perception or manipulation skills are not enough to support commercial deployment. The real challenge is to enable robots to autonomously and dynamically combine multiple capabilities in unknown scenarios, building a complete intelligent system that is stable and reliable and can adapt its configuration in response.
For physical AI, model capability is just the starting point. Capability orchestration, real-time scheduling, state management, and behavior-constraint mechanisms are becoming key to enabling robots to enter open, real-world environments. Generalization capability in robots is regarded as a key capability for scaling up robot technology and achieving large-scale deployment. How to support this capability with efficient computing is one of Arm’s core focus challenges.
Around this viewpoint, Federico Pecora recently had in-depth exchanges with media such as Zhidx (智东西). He told Zhidx that promoting large-scale deployment of robots requires not only continuous progress in AI models, but also coordinated evolution of underlying hardware and system architecture. Arm’s computing platform already has capabilities that are crucial for real-world robots, such as high energy-efficiency computing, real-time responsiveness, and safety isolation technologies. Arm’s extensive experience in the automotive domain is also applicable to various physical AI scenarios.
But robot applications face additional challenges. Robots need to handle objects of various forms and, in principle, be able to execute a wide range of different tasks. Therefore, the computing architecture must be able to cope with these additional degrees of freedom—supporting more parallel perception and planning models—while also meeting more complex control requirements that come with higher computational overhead.
In his view, another key issue for future computing platforms is how to support capability reuse and composition across different robots. What the industry needs is a unified, open, and extensible computing foundation. No matter what robot form factor, computing configuration, or application scenario is used, software can be developed and deployed on this platform—reducing development complexity and accelerating innovation deployment.
He predicts that customized capability will become very important. The challenge robots face is not only supporting intelligent capabilities through accelerators, CPUs, and memory bandwidth, but also implementing these capabilities within power consumption and thermal limits. In the future, robot computing platforms will need to be flexibly scalable across multiple dimensions such as CPU, accelerators, memory, and bandwidth to meet the needs of different scenarios, while still keeping the underlying technical foundation unified.
“Arm’s core mission has always been to empower the ecosystem and developers. By providing capabilities such as ISA consistency (ISA parity), developers can complete development and training in the cloud, then migrate the software directly to edge and terminal robot platforms—without large-scale rework or re-adaptation.” Federico Pecora said. This is one of Arm’s most important advantages as a computing platform.
I. Generalization capability is the industry’s core breakthrough point
From the perspective of industry development trends, robot capability evolution is going through three stages.
The first stage is cross-object generalization, meaning the robot can handle different types of objects within the same task flow without needing to retrain or reprogram for each object. This capability has been validated in structured scenarios such as sorting, logistics, and retail.
The second stage is multi-task intelligence. A unified intelligent platform supports execution of multiple tasks. Robots no longer serve a single fixed workflow; instead, they can switch among different capability combinations based on task requirements.
The third stage is achieving system-level self-adaptation. At that time, both end users and the robots themselves will be able to adjust capabilities based on changes in the environment, without needing to redevelop, retrain, or redeploy the system.
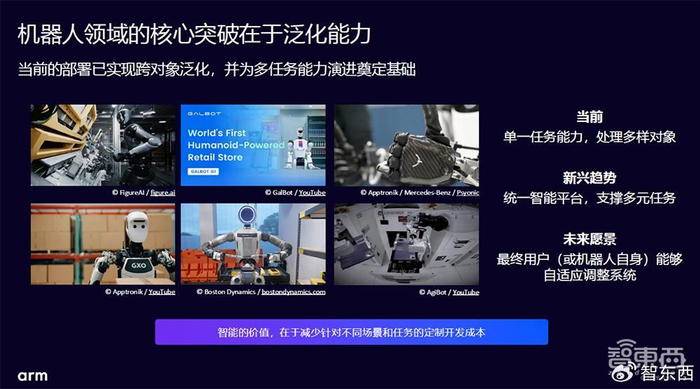
The commercial value of generalization capability lies in significantly reducing the cost and complexity of adapting robots to new scenarios, new workflows, and new tasks.
A daily scenario can directly illustrate the real-world value of generalization capability. Imagine a user taking a humanoid robot to a supermarket, giving instructions: “Push a shopping cart and follow me. You go get a bag of 10 kilograms of rice; I’ll pick out vegetables, and we’ll meet later in the dairy section.”
These instructions are not complicated in daily life, but they place very high demands on a robot system. In public places with dense foot traffic and no pre-built environment maps, robots may not have been trained specifically for tasks like “push a shopping cart.” To complete the task, the robot must adapt to changes during execution and build or adjust its own capability structure in real time, rather than calling a fixed solution trained in advance.
Many individual capabilities can already be achieved through targeted training, model optimization, and engineering implementation. However, the real challenge is how to enable robots to autonomously coordinate and combine these capabilities into a physical AI system that can continuously perceive, decide, and act to accomplish complex tasks in the real world.
For example, in a shopping scenario, it must not only be able to push the cart and follow the user, navigate autonomously without a map, identify products, and carry heavy items. It must also be able to adjust its own behavior and motion model in real time. When collaborating with people, it must comply with predefined behavioral constraints and continuously deliver reliable, stable results in dynamically changing environments.
During conversations with the media, Federico Pecora also shared that an important reason the industry is optimistic about the humanoid robot form factor is that it carries the potential and hope for robots to achieve generalization and adaptability. He expects it to adapt to new scenarios and requirements more easily than purpose-built robots designed for specific tasks; maintain stable performance; and be quickly transferable to entirely new tasks and application scenarios. His R&D experience can also be transferred to other robot platform form factors.
II. Large-scale deployment of robots: four major system-level challenges
As robots move from technology demonstrations to real-world deployments, the problem the industry needs to solve is no longer whether a single model is sufficiently advanced, but rather how to enable a large number of heterogeneous capabilities to coordinate efficiently within the same system.
Arm believes that the next phase of large-scale robot deployment will be driven by four major system-level challenges.
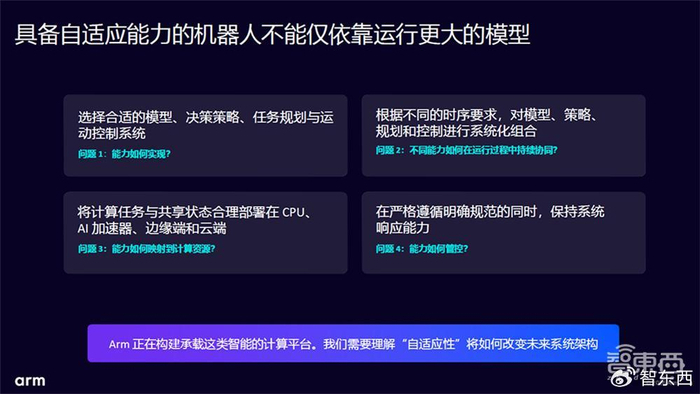
1. How are capabilities implemented?
A robot cannot rely on a single model to complete all tasks. Instead, it needs to match appropriate models, strategies, planners, and controllers for different stages. For example, a vision-language action model can be used to generate probing actions; a vision-language model can be used to identify actionable objects in the environment; a large language model can help generate controller logic; and a parameterized controller is responsible for outputting safe and reliable actions. These modules must run concurrently, share memory and bandwidth resources, and jointly generate the final behavior.
2. How can different capabilities continuously coordinate during runtime?
Robot workloads in the real world operate at different time scales: collision checking must respond immediately; navigation and manipulation need continuous updates; while higher-level reasoning such as “locate the rice” often appears in sudden, asynchronous ways. Without a clear temporal structure and priority scheduling, these capabilities may compete for computing resources, leading to response delays—affecting not only system efficiency, but potentially also creating safety risks.
3. How are capabilities mapped to computing resources?
Without a pre-built environment map, a robot needs to rely on local intelligence to perform perception, scene understanding, and path planning, while gradually building semantic maps that multiple models can share. Requirements for responsiveness, autonomous decision-making, and safety mean that a large amount of intelligent computation must be carried out locally on the robot. This brings major system-architecture challenges: how to appropriately divide computational tasks among the CPU, dedicated accelerators, memory, and communication links—maximizing the benefits of heterogeneous computing while minimizing data-movement costs to achieve higher performance and energy efficiency.
4. How are capabilities constrained and governed?
As robots gain stronger adaptive abilities, the industry needs to look beyond basic safety issues such as collision avoidance, speed limits, and force control. It must also consider higher-level constraints such as spatial and temporal rules, task preferences, and behavioral norms in specific scenarios. Black-box AI strategies are often difficult to inspect, diagnose, and constrain robot behavior.
Therefore, even as the system continues to evolve, safety barriers, runtime assurances, control problem modeling, and fallback controllers must remain effective as the system changes. This requires shifting customized development away from approaches that rely on experience and ad hoc engineering, toward a clear, deployable behavioral protection framework with enforceable constraints.
To move forward in solving these four problems, Federico Pecora said that Arm will continuously advance related work through its research team led by Arm. On one hand, it will keep conducting research and actively share research results with the outside world; on the other hand, it will work closely with ecosystem partners in areas such as semiconductors, sensors, and actuators.
III. Generalization capabilities will deliver commercial value in layers, expanding the range of covered use cases
Federico Pecora proposes that the deployment of generalization capabilities will continue to release commercial value in layers:
The first level is enabling cross-task reuse of software, models, and skills.
Higher-level generalization capability allows end users—such as factory operators, supermarket managers, and robot operators—to complete adaptive configuration of robots through demonstrations or language instruction prompts.
At the highest maturity level, robots can achieve fully autonomous adaptation driven by environmental context, which greatly reduces system integration costs and broadens the range of use cases that robot systems can cover.
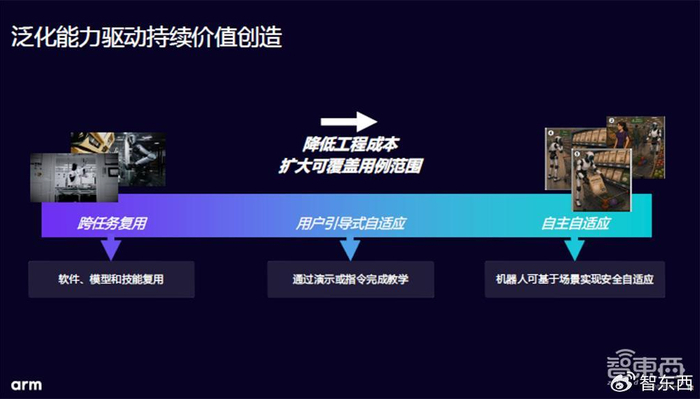
Fundamentally, this is first a question of robotic system architecture—how to organize a robot’s perception, execution, and behavioral capabilities. Only second is a question of computing architecture—how to configure and supply underlying computing power.
Today, robot architectures themselves have not truly matured yet, and there is still plenty of room for optimization to be explored. In the future, these architectural evolutions and optimizations may very likely shape the direction of computing architecture development to some extent in return.
As robots move from executing a single task to system-level self-adaptation, the importance of computing platforms is shifting—from supporting the execution of a single model to supporting the coordinated operation of an entire intelligent system.
With the technical advantages of “high energy efficiency, high reliability, and high adaptability,” Arm architecture solutions (including CPU, accelerators, and MCUs) provide rich compute configurations and safety features, and are already widely used in various robot products.
According to Federico Pecora, to address the main challenges of achieving robots that adapt to all scenarios, Arm plans to tackle related problems through specialized robot research and collaborate with ecosystem partners in the physical AI domain to build a next-generation computing architecture for physical AI and general-purpose robots.
At the same time, Arm plans to work with the global academic community to advance related frontier research, bringing together innovation outcomes from academia and industry and validating them across various commercial platforms for real-world deployment. Ultimately, this will promote the development of robot systems with system-level intelligence.
Conclusion: Arm provides a unified computing foundation for robot system capabilities
The robot industry faces a gap between innovation priorities and actual industrial needs. For a long time, academia has tended to break down problems into specialized research areas, driving continuous breakthroughs in individual capabilities such as perception, planning, control, and learning. In contrast, industry is more focused on product deployment and validating commercial value—prioritizing the integration of functions that meet current business requirements. This creates a gap between capability innovation and deployable robotic systems.
The industry needs a universal computing foundation that can connect, organize, and coordinate these capabilities in large-scale deployment scenarios. Arm is playing a role in this critical link. By providing an open computing platform and a large ecosystem, Arm aims to help the industry turn individual technology breakthroughs into reliable system-level intelligence, accelerating robot technology’s transition from the lab to large-scale deployment.
Through a complete computing ecosystem that spans sensors, real-time control, AI computing, edge computing, and cloud infrastructure, Arm continues to evolve the computing architecture and toolchain. This provides robots with a unified computing foundation, helps developers reuse software and efficiently schedule workloads across different hardware platforms, and significantly lowers the barriers to innovation and large-scale deployment.
China’s robotics industry is witnessing a wave of innovation and emergence. In this important market, Arm plans to continue working with local ecosystem partners to jointly push adaptive robot technologies toward broader real-world applications.